Yixiao Tao

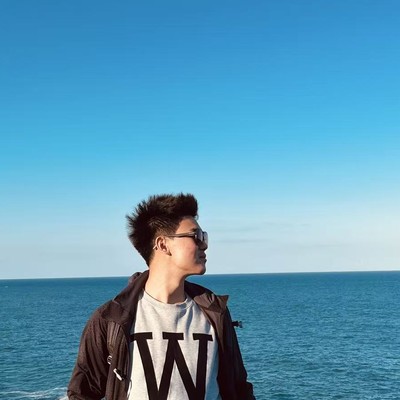
Yixiao Tao by the sea

Projects

GitHub
Independent ProjectSLAM / Robotics

LoopLens

Visual loop closure & pose-graph optimization

Detects revisited places, estimates relative poses, and corrects trajectory drift. Combines DINOv2 retrieval, DISK + LightGlue matching, stereo-depth PnP, and a custom SE(3) pose-graph optimizer.

DINOv2LightGluePnP + RANSACSE(3)
Implementation & evaluation

Implemented a sparse Gauss–Newton optimizer on SE(3), including Lie-group updates, analytical Jacobians, and separate translation and rotation weights. Loop constraints come from stereo depth and geometrically verified image matches.

Evaluated offline on all 4,541 frames of KITTI 00, using an ORB-SLAM3 stereo trajectory with its loop-closing thread disabled. ATE RMSE is measured after rigid alignment without scale correction. These results cover one sequence; online operation has not been evaluated.

A separate Gardens Point study compares CNN and transformer retrieval, causal sequence matching, and geometric verification. Acceptance thresholds are fitted on validation data and frozen before test, keeping ranking improvements separate from acceptance reliability.

Loop closure on KITTI 00
  1. Retrieve
  2. Verify + PnP
  3. Optimize
Ground truthBeforeAfter
KITTI 00 trajectory and translation errorGround truth is a dotted grey line, the trajectory before loop closure is dashed, and the optimized trajectory is solid. All curves use neutral greys. The lower plot shows per-frame translation error after rigid alignment, without rescaling. ATE RMSE decreases from 4.335 to 1.956 metres over 4541 frames. −300 0 300 x (m) 0 250 500 z (m) 0 2000 4000 Frame 0 5 10 Error (m)
55% lower ATE RMSE

4.335 m → 1.956 m

97% ground-truth distance < 5 m

763 accepted loop pairs

Recorded trajectories · rigid alignment · single-sequence offline evaluation.

About

I work on spatial intelligence, and the part of robotics where large models meet geometry.

EDUCATION

2025 — 2026

University College London

MSc Robotics and Artificial Intelligence

2021 — 2025

Xiamen University Malaysia

BEng Computer Science and Technology

2018 — 2021

Ningbo Xiaoshi High School

LANGUAGES

Python · C++ · Java

FRAMEWORKS & TOOLS

PyTorch · React · FastAPI · Docker

ROBOTICS & PERCEPTION

SLAM · Computer vision · Multimodal perception · Motion planning · MPC · Kalman filtering · Legged robotics

Footprints

Places I've been

Loading the travel map…

Contact